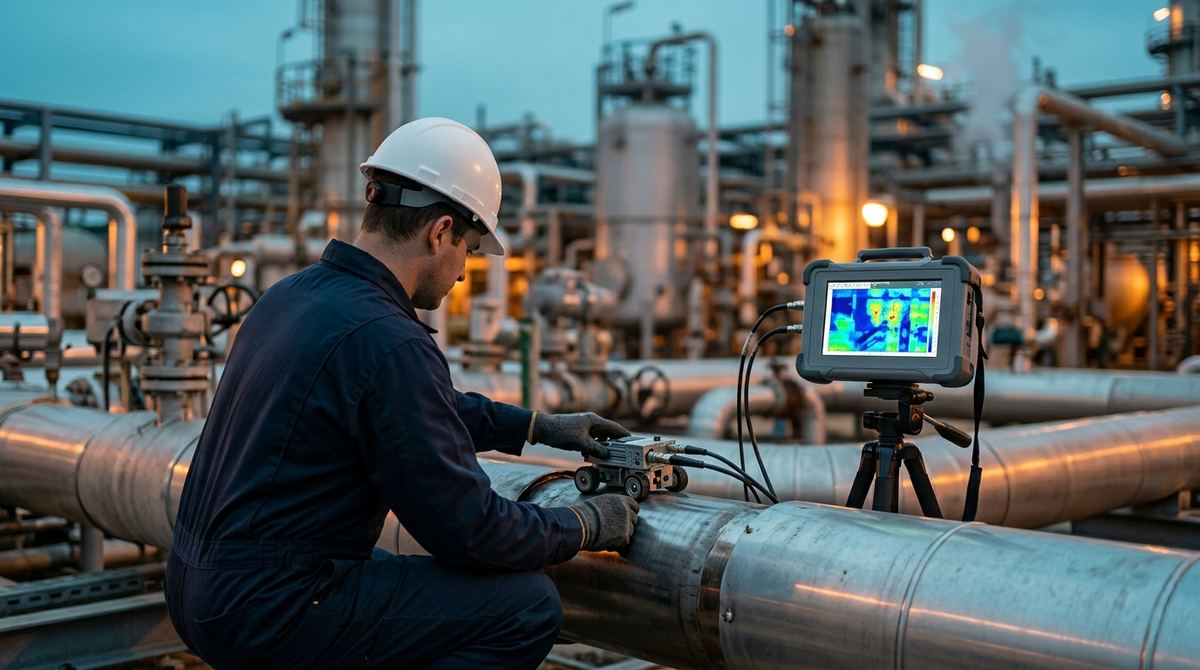
An insulated line passes twelve thickness readings, all within tolerance, and six months later it leaks between two of those points. The pit that holed it sat right there, in the space the measurement grid never touched. It's the scenario every asset integrity inspector knows, and the method is to blame more than the reading. An ultrasonic thickness gauge measures one point at a time, and however tight the mesh, some surface always stays unseen between one point and the next. Corrosion mapping changes exactly that. Instead of sampling the wall at a few points, it reconstructs it as a dense matrix of measurements, and the result isn't a number but a map.
The worst spot rarely sits under a reading
Spot thickness measurement is a solid, standardized technique: ISO 16809, in its 2025 edition, defines how thickness is determined from the time of flight of the ultrasonic pulses, by contact or immersion. On general, uniform corrosion, where the wall thins predictably, a few readings at representative points are enough to estimate the rate and the remaining life. That's how API 570 sets up the monitoring of in-service piping, with registered condition monitoring locations (CMLs) and the interval fixed at the lesser of a maximum and half the calculated remaining life. The picture changes when corrosion isn't uniform. Pitting, localized erosion downstream of an elbow and attack under a deposit all play out over a few millimeters, and a coarse grid averages them out or misses them entirely. Hunting for them with scattered readings is like judging the worst pothole in a road by measuring its depth every ten meters. How to get a single reliable reading, and when it is enough, is explained in the article on the ultrasonic thickness gauge for corrosion measurement.
From gauge to map: encoder, C-scan, B-scan
The move from point to matrix is mechanical before it's conceptual. A motorized or manual scanner carries the probe over the surface, and an encoder records its position at every measurement, so each thickness value comes with its own coordinate. The software lays the data out in a false-color plan view, the C-scan, where thinned zones show up as patches, and in vertical sections, the B-scans, which reveal the wall profile along a line. Phased array is today the preferred technique, because a single probe covers a wide strip on each pass, cuts the time and raises the data density. It's the same principle set out in the phased array (PAUT) guide, applied to mapping rather than to hunting cracks in welds.
Density, though, has to be decided case by case. A fine grid, around one millimeter, reveals pitting and fine contours; a coarse mesh covers large areas fast but can miss the small indications. And this is where the C-scan alone can mislead. A study in Materials (Tai and colleagues, 2023) on A36 steel showed that simulated defects of 10, 15 and 20 mm in diameter were clearly identified in shape, while the 5 mm one didn't return a clean outline. The measured depth deviation stayed below 0.8 mm all the same. The shape of the corroded surface also affects the result. Work published in Smart Materials and Structures (2016) documented how corrosion-induced morphology changes alter the rates measured by ultrasonic monitoring. The smaller pits are seen and sized better in B-scans than in the plan-view map, and stopping at the C-scan risks losing them. Within industrial ultrasonic testing (PAUT/TOFD), mapping is the application built for corrosion control.
Piping, tanks, and corrosion under insulation
The sectors where mapping pays off are those where a failing wall has large consequences: oil & gas, power, chemical, refining. The governing standard changes with the asset, and it helps to have it clear before writing an inspection plan.
- ISO 16809:2025: ultrasonic thickness determination, by contact or immersion, the physical basis of both spot measurement and mapping.
- API 570 and API RP 574: inspection and thickness measurement of in-service piping; RP 574 covers techniques and extent and notes that screening methods (guided wave, Lamb wave) count only as a complement to periodic quantitative examinations.
- API 653: aboveground storage tanks; bottom-side floor corrosion, which can't be seen, is searched for with Magnetic Flux Leakage and sized by UT, while shell thickness is verified ultrasonically.
- API RP 583: corrosion under insulation (CUI); for carbon steel the risk window runs roughly from −12 to 175 °C, with the most severe attack between 77 and 110 °C.
CUI is precisely where the matrix earns its place over the point. The wall under the insulation can't be seen, corrosion is often localized, and the temperature window says where it's likely but not how deep it runs. Opening the lagging at two points and measuring them is a statistical gamble, whereas mapping the at-risk zone, once located, gives you data you can act on.
Heat exchangers add a case of their own: bundles of hundreds of tubes where shell-side corrosion, inlet erosion and deposits spread anything but evenly, and where a map tells which tubes to plug and which to keep. Across all these assets the matrix has a second value beyond detection, because it's a repeatable record. Rescanning the same area months later and overlaying the two maps gives the real corrosion rate across the whole surface, and that's the figure the next inspection interval can be set on, on firmer ground than a handful of readings.
When a thickness gauge is still enough
Not everything should be mapped, and saying so is part of the trade. For general, slow corrosion on an accessible surface, a grid of spot readings managed to API RP 574 is enough and costs a fraction. You register the CMLs, compute the two corrosion rates and use the more conservative one to derive remaining life, without a scan. Mapping comes in where the damage is localized or its morphology matters, or where the detailed record serves to compare the asset over time. There's a physical limit to budget for as well: UT mapping wants contact with the bare wall, so under insulation or coating you have to open a window or remove the lagging over the area to be checked. The choice, at that point, is clear-cut. Either you accept the cost of exposing the wall where risk is high and map it properly, or you rely on screening to decide where to open, knowing it points to the zone but leaves the remaining depth open.
Have a suspect area to map?
Tell us the asset, material, temperature and expected damage mechanism, and we'll arrange a field demonstration of corrosion mapping on one of your areas, with a C-scan and a comparison against spot readings.
Email us Message us on WhatsAppFrom one pit to an unplanned shutdown
A five-millimeter pit missed by a coarse mesh is, on paper, a detail. On the line it becomes the point a leak starts from; on the unit it becomes an unplanned shutdown, with production stopping while the section is isolated and repaired. Mapping is there to break that chain at the start, while the defect is still a patch on a C-scan rather than a leak. Anyone managing the integrity of piping, tanks or exchangers, and relying today on spot readings on critical assets, has a simple way to measure the gap. Have a suspect area mapped, ideally one already passed by the gauge, and see what the matrix returns. An honest assessment also says when spot readings are already enough and mapping would be an extra cost. Scanning systems and probes are on the page for industrial ultrasonic testing instruments for PAUT and TOFD. For the buying criteria of a phased array instrument, see the article on how to choose a PAUT and TOFD instrument.
What to send us for an assessment
To judge whether to map, where and with which configuration, we need a few data points:
- asset type (piping, tank, vessel, heat exchanger), diameters and nominal wall thicknesses;
- material, operating temperature and presence of insulation or coating;
- expected damage mechanism and history of thickness readings at the CMLs;
- governing code (API 570, API 653, API 510) and required assessment criterion;
- area to cover, accessibility and available outage windows;
- data format required to compare successive campaigns.
You can send them by email to info@pitech-solution.com or on WhatsApp, attaching photos, drawings or the latest readings.
Frequently asked questions on ultrasonic corrosion mapping
What is the difference between corrosion mapping and an ultrasonic thickness gauge?
The physics is the same, and ISO 16809:2025 applies to both. What changes is the volume of data: a gauge survey produces a few dozen readings per line, while mapping at a millimeter step produces thousands per square meter, each with its coordinate. That is why mapping also needs a different way to store and compare data, to be planned before the first scan.
When does mapping pay off over spot readings?
A practical signal is the scatter of the readings. When repeated measurements at the same CML vary more than the instrument's uncertainty, or when one point drifts off the trend of its neighbors, corrosion is probably localized and mapping the area becomes the next move. Where readings stay consistent survey after survey, the spot grid is still enough.
What resolution is needed to detect pitting with UT mapping?
What counts is the ratio between grid step and the size of the pit to be found: with a step close to the pit diameter, the defect can fall between two points and appear smaller or shallower than it is. The step is therefore set from the smallest pit the assessment criterion requires to detect, and the map is read together with the B-scan sections.
Which standards govern thickness measurement and corrosion inspection?
Ultrasonic thickness determination is covered by ISO 16809:2025 (contact or immersion, by time of flight). For in-service piping the references are API 570 (intervals and criteria) and API RP 574 (practices and measurement techniques). For aboveground storage tanks API 653 applies, which for bottom-side floor corrosion uses Magnetic Flux Leakage with UT confirmation. Corrosion under insulation is addressed by API RP 583, which for carbon steel identifies a risk window roughly between −12 and 175 °C, with the most severe attack between 77 and 110 °C.
Can corrosion under insulation be mapped without removing the insulation?
UT mapping needs contact with the bare wall, so under insulation or coating you have to open an inspection window or remove the lagging over the area to be checked. The efficient way is to use screening methods first to decide where to open, knowing they indicate the at-risk area but not the remaining wall thickness. The CUI temperature window (API RP 583) also helps judge where corrosion is most likely. Then you map the chosen spot. Screening says where to open, mapping how much metal is left.